Add Figure 1 at static/images/teaser.png
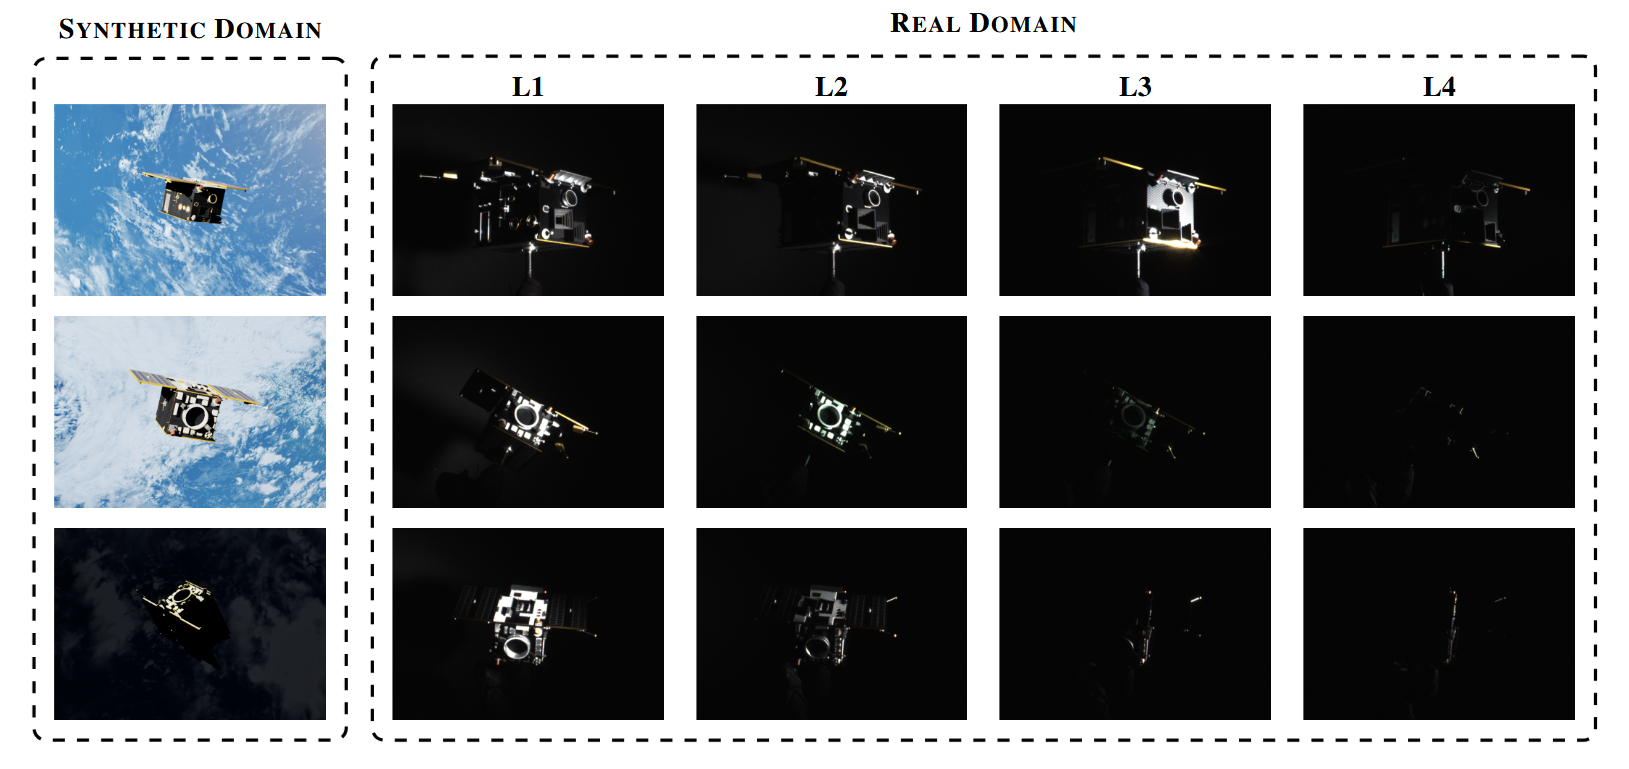
Deep learning has become the dominant paradigm for vision-based spacecraft pose estimation, where models are predominantly trained on synthetic data due to the prohibitive cost of acquiring real in-orbit imagery. When deployed, these models suffer significant performance degradation due to the sim-to-real domain gap, which existing benchmarks address by pairing synthetic training data with Hardware-in-the-Loop (HIL) real imagery. Yet a critical factor remains consistently overlooked: in real orbital scenarios, illumination varies with the spacecraft's position along its orbit, inducing severe appearance shifts that existing benchmarks neither control nor study.
We introduce ECLIPSE, the first benchmark designed to isolate illumination as an independent experimental variable. ECLIPSE pairs a large-scale photorealistic synthetic training set with a fully labeled HIL evaluation set of 14 approach trajectories, each replayed identically under 4 controlled lighting conditions, enabling rigorous evaluation of illumination-robust and domain-adaptation methods. Through this controlled design, our experiments confirm that illumination is a major driver of performance degradation in spacecraft pose estimation, both within the real domain and across the sim-to-real gap.
Each real trajectory is recorded four times with the same motion, once per lamp position, so only the lighting changes.

This work was supported by the Luxembourg National Research Fund (FNR) under the project reference BRIDGES/2025/IS/19855391/U-ADAPT, and by Infinite Orbits. Experiments were performed on the Luxembourg national supercomputer MeluXina at LuxProvide.


@inproceedings{chenni2026eclipse,
  title     = {{ECLIPSE}: A Spacecraft Rendezvous Trajectories Dataset
               with Controlled In-Orbit Lighting Conditions},
  author    = {Chenni, Nidhal Eddine and Rathinam, Arunkumar and
               Ali, Abid and Aouada, Djamila},
  booktitle = {Advances in Neural Information Processing Systems (NeurIPS),
               Track on Evaluations and Datasets},
  year      = {2026}
}